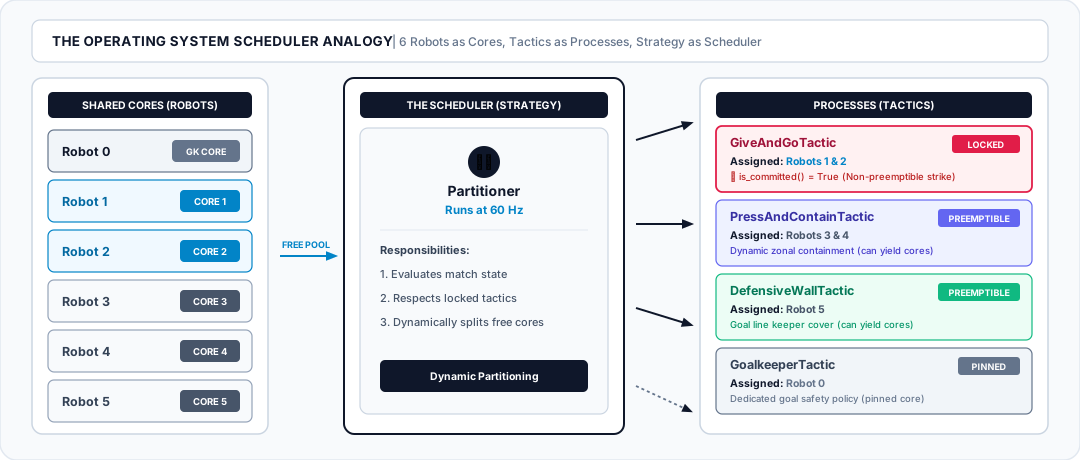
Strategy = Tactics × Orchestration
Why Behavior Trees broke down for multi-agent coordination, how modeling our scheduler after an OS kernel solved dynamic regrouping, and the three safety invariants that eliminate race conditions.
Why Behavior Trees broke down for multi-agent coordination, how modeling our scheduler after an OS kernel solved dynamic regrouping, and the three safety invariants that eliminate race conditions.
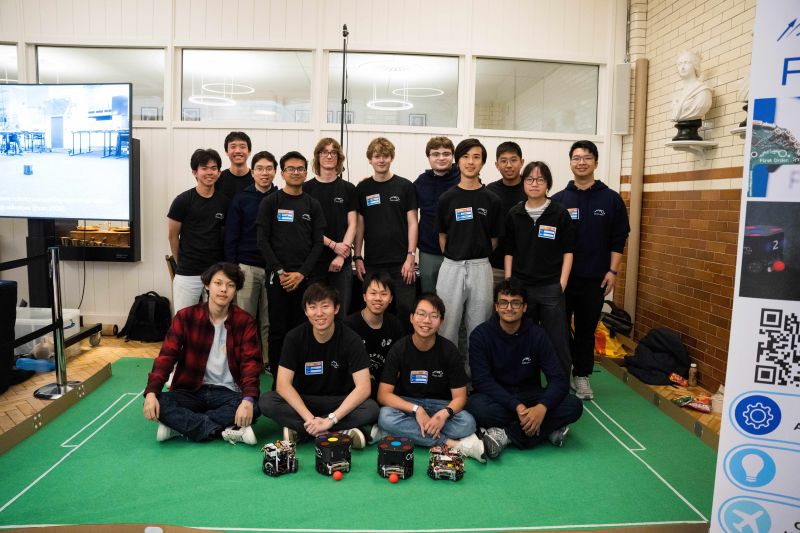
An architectural overview of our RoboCup Small Size League robot control stack, lessons from our Great Exhibition Road Festival milestone, and open challenges as we scale to a full 6v6 squad.